Autonomous Racing
F1TENTH, ROS2
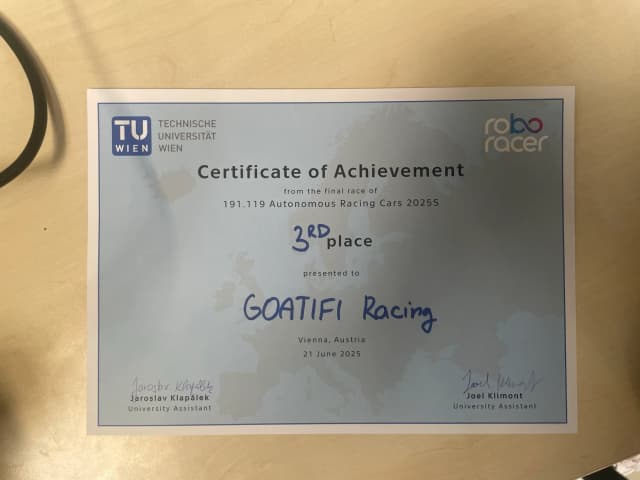
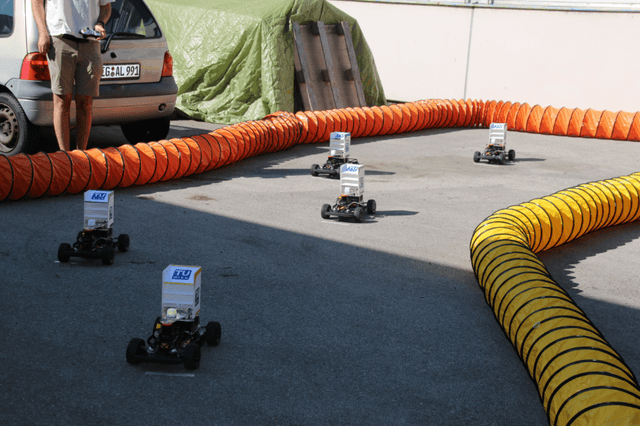
1st place and 3rd place in autonomous racing challenges; delivered real-time navigation with SLAM+LiDAR and path tracking in ROS2.
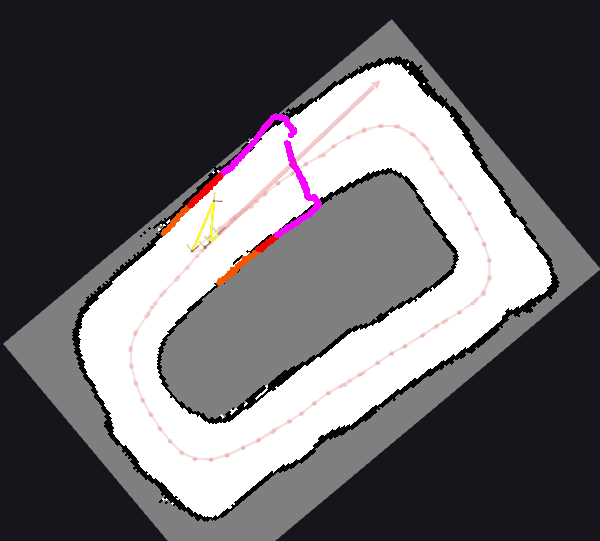
Integrated SLAM, obstacle avoidance, and path tracking (Pure Pursuit, Disparity Extender) with ROS2 tooling, telemetry, and reproducible test runs for rapid iteration.
Highlights
- Placed 1st and 3rd in autonomous racing challenges (team result).
- Integrated SLAM + LiDAR perception for localization and track understanding.
- Implemented obstacle avoidance and path tracking (Pure Pursuit, Disparity Extender).
- Improved iteration speed using telemetry and reproducible test runs.
What I did
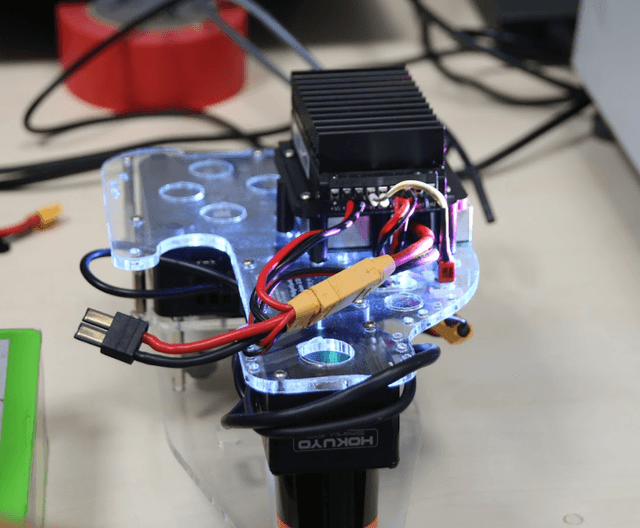
- Integrated ROS2 nodes and sensor pipeline; validated timing and real-time behavior.
- Implemented and tuned controllers (Pure Pursuit) plus safety constraints.
- Added evaluation tooling (telemetry, logging) to compare controller/perception changes.
Stack
- ROS2
- C++/Python
- LiDAR
- RViz
- Foxglove
- Navigation